Model-Based Reinforcement of Kinect Depth Data for Human Motion Capture Applications
Jul 10, 2013·,, ·
0 min read
Luis Vicente Calderita
Juan Pedro Bandera
Pablo Bustos
Andreas Skiadopoulos
Abstract
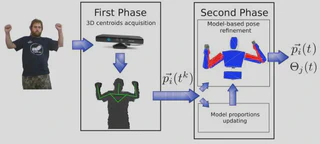
Contemporary motion capture systems leverage affordable depth sensors and open frameworks such as OpenNI to track human movement without invasive equipment, but the plausibility of the resulting poses is not verified. This work introduces a model-based pose generator that complements the OpenNI human tracker by applying kinematic constraints, removing implausible postures, and reducing sensor noise while adapting to individual body dimensions. The system integrates a PrimeSense sensor, OpenNI tracking, and a kinematics-based filter. Testing demonstrates performance improvements over standard OpenNI at minimal computational expense.
Type
Publication
Sensors, 13(7), 8835–8855
